Tactile sensing for a dexterous hand
A CRAFT hand with working webcam teleoperation, now being developed into a platform for fingertip tactile sensing.
A working hand, a sensing platform in development
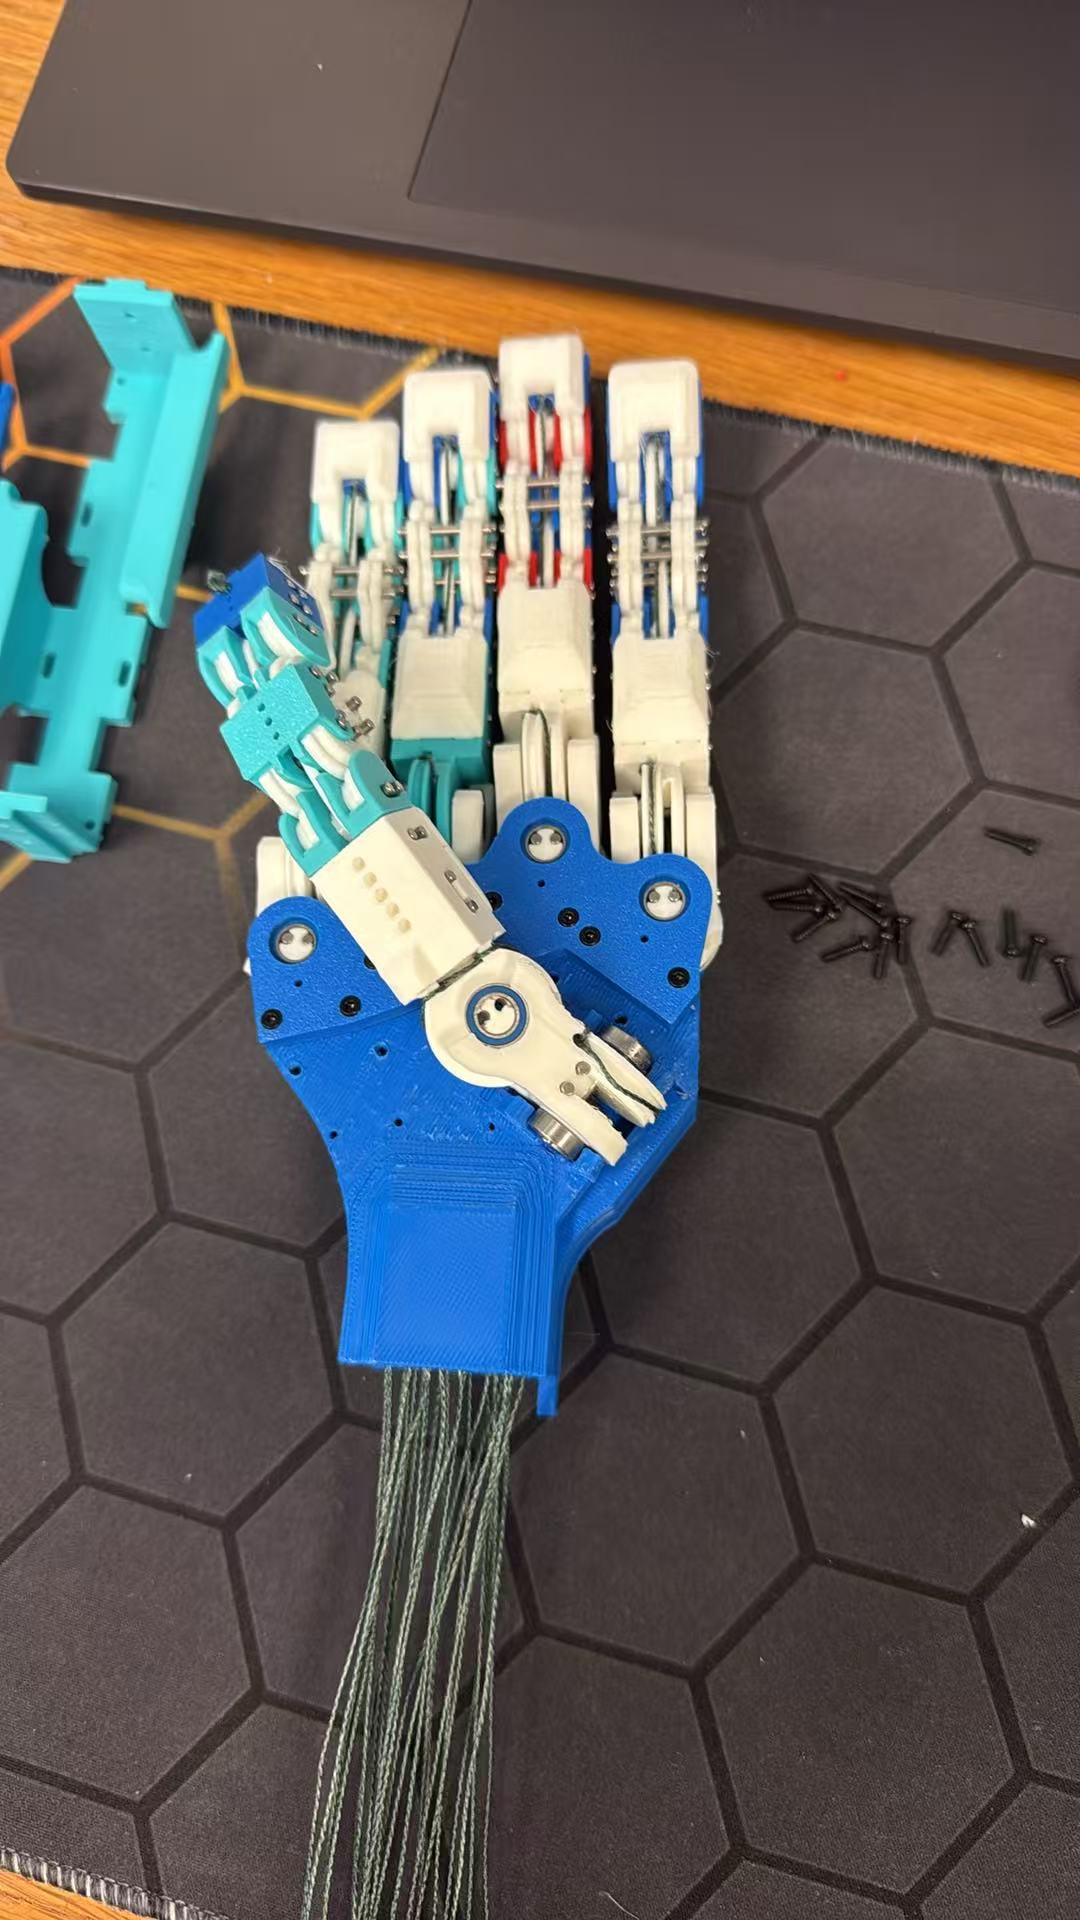
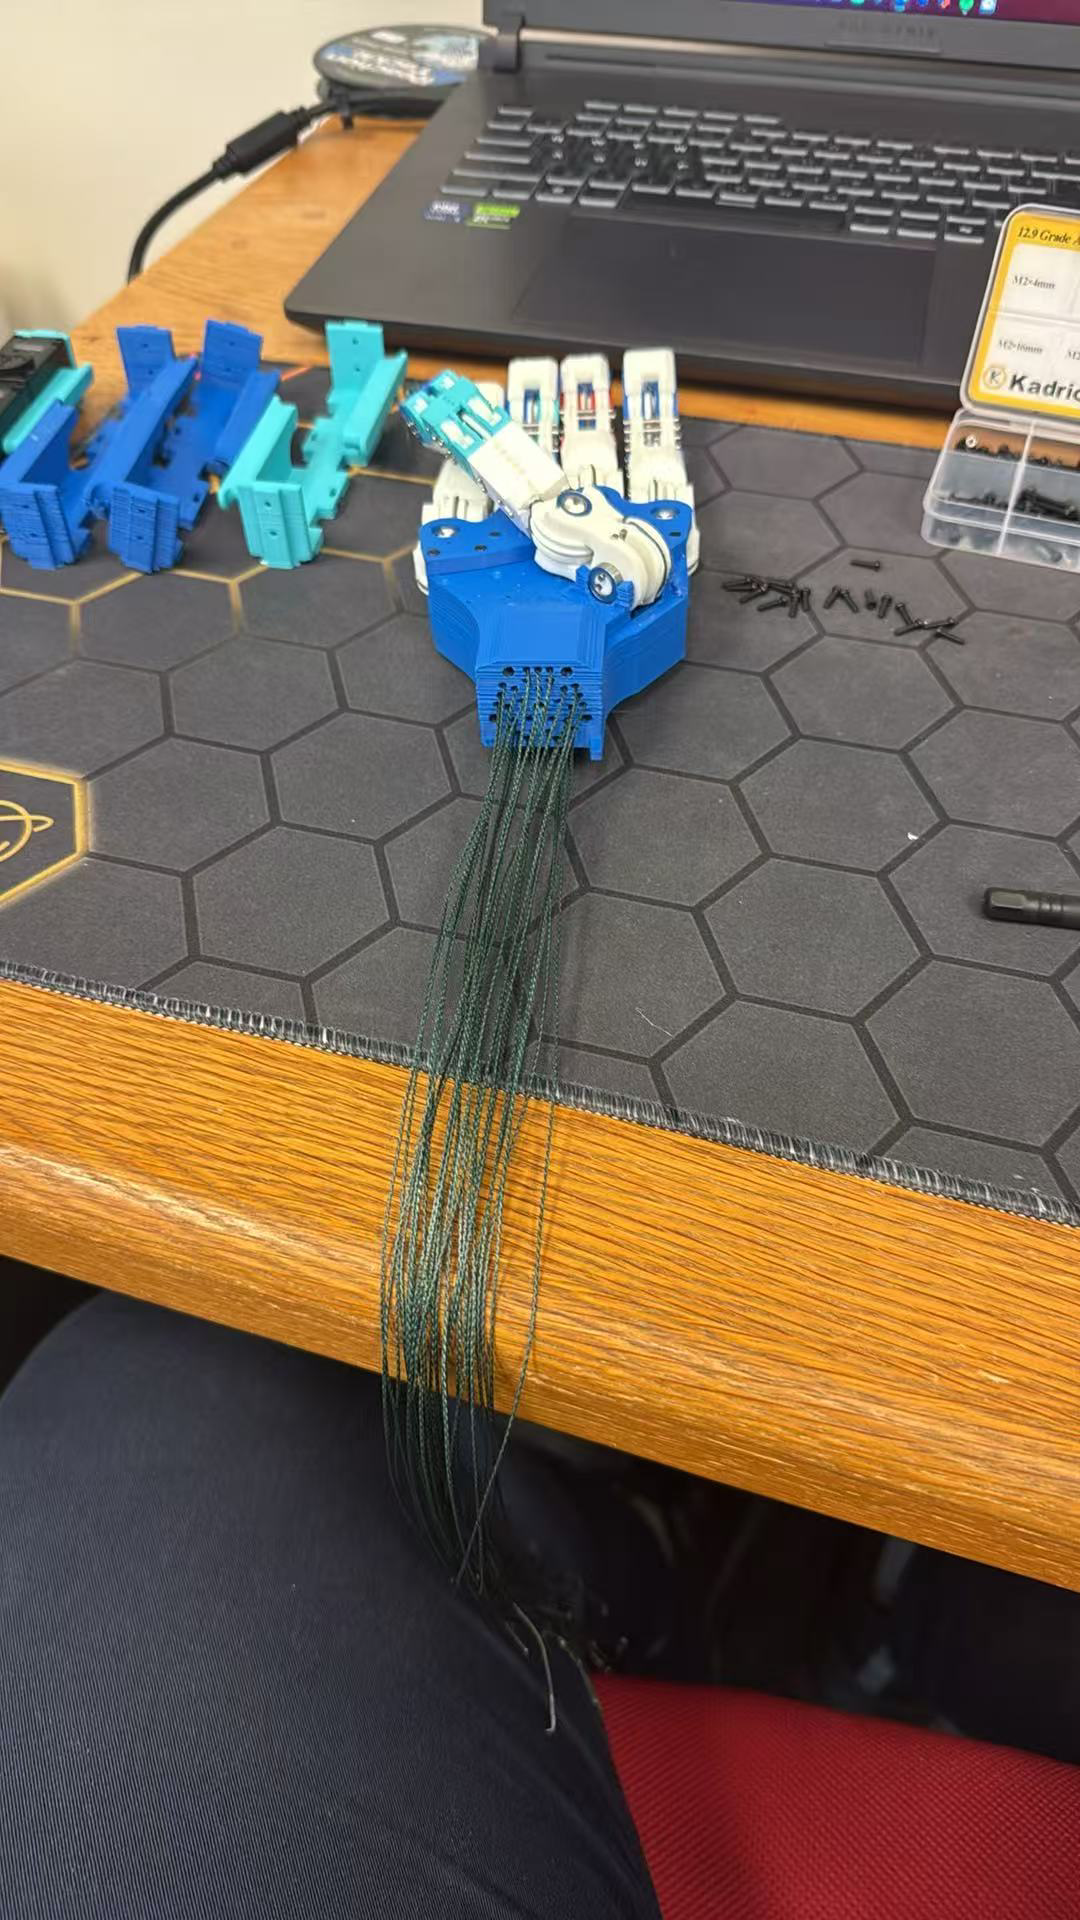
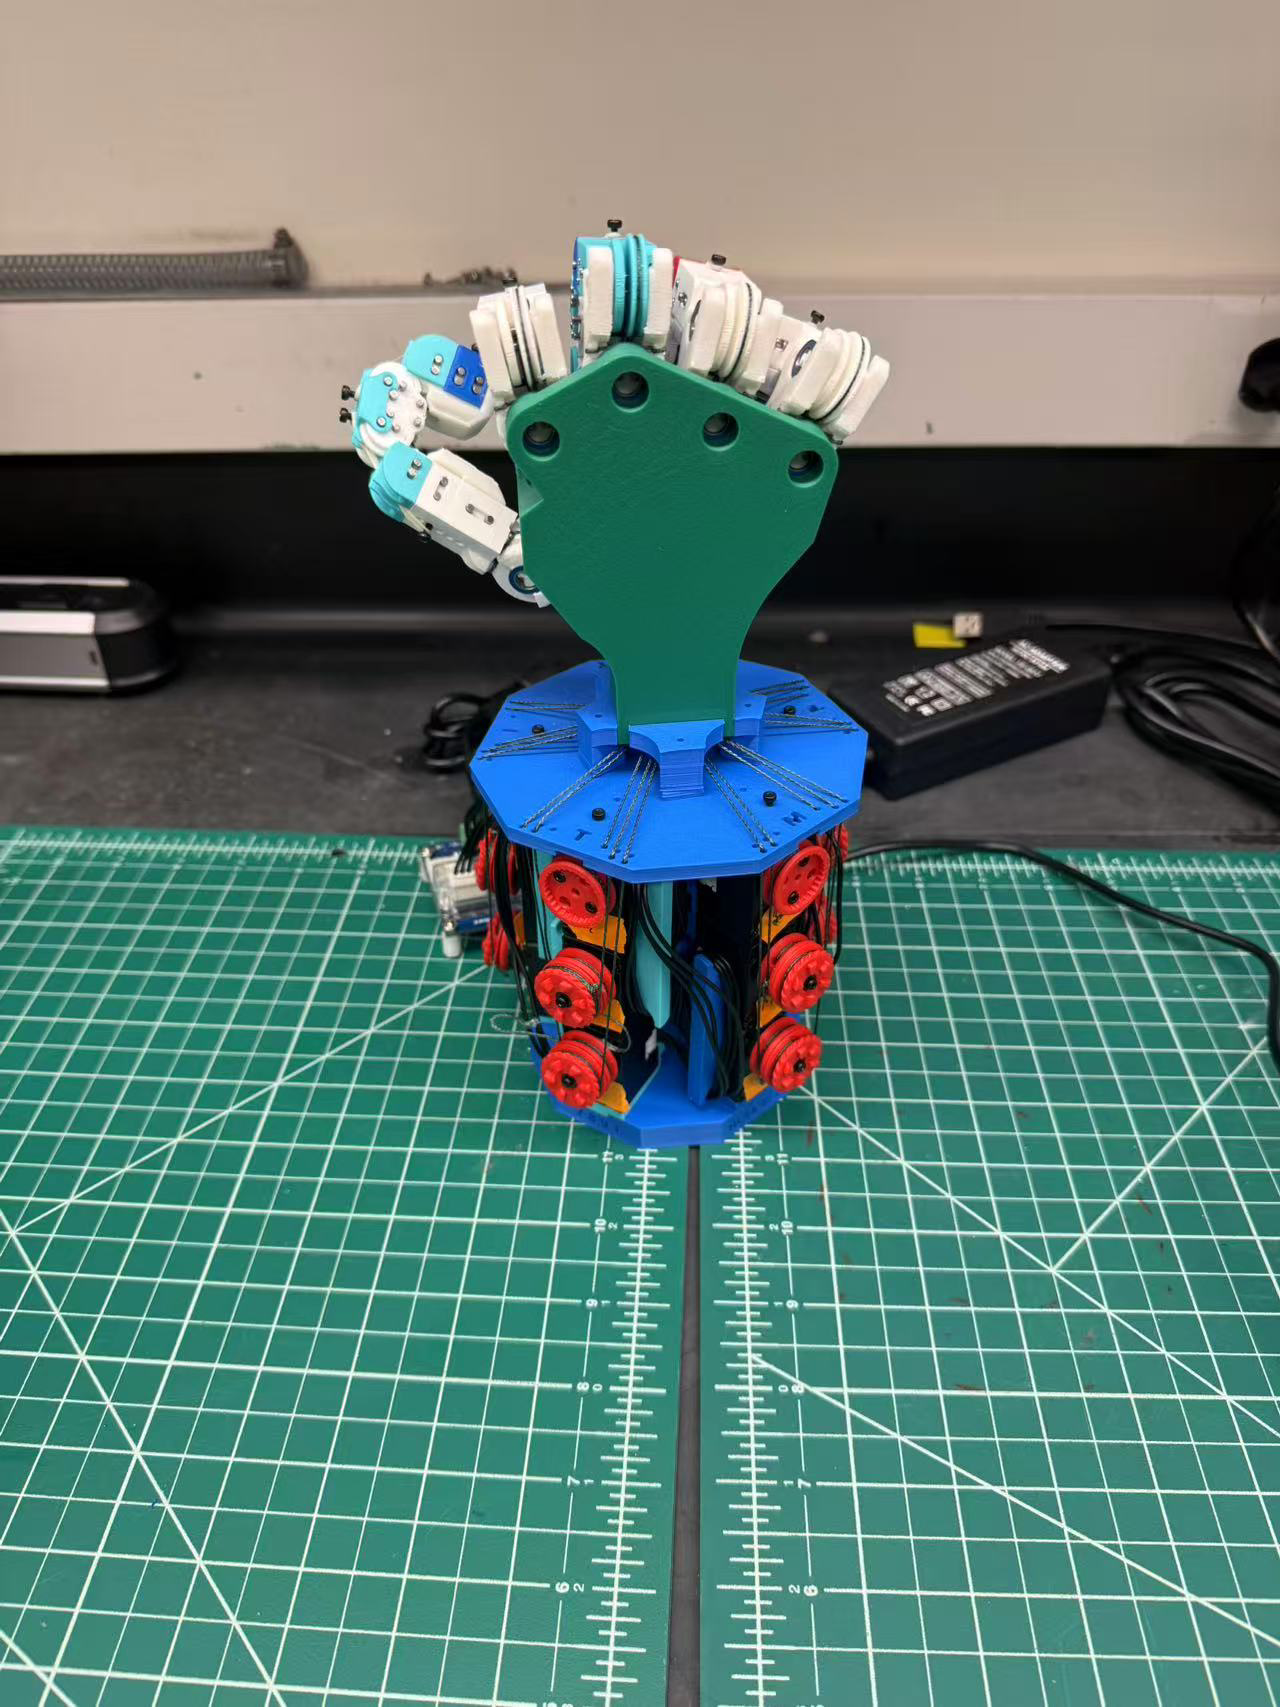
I assembled and integrated the open-source CRAFT hand following its design and guides, then brought up its camera-based teleoperation workflow. The mechanical build and teleoperation are working. My current focus is fitting tactile sensing onto the fingertips.
The platform uses 15 Dynamixel servos to actuate the tendon-driven fingers. The photos document assembly, tendon routing, and the completed hand.
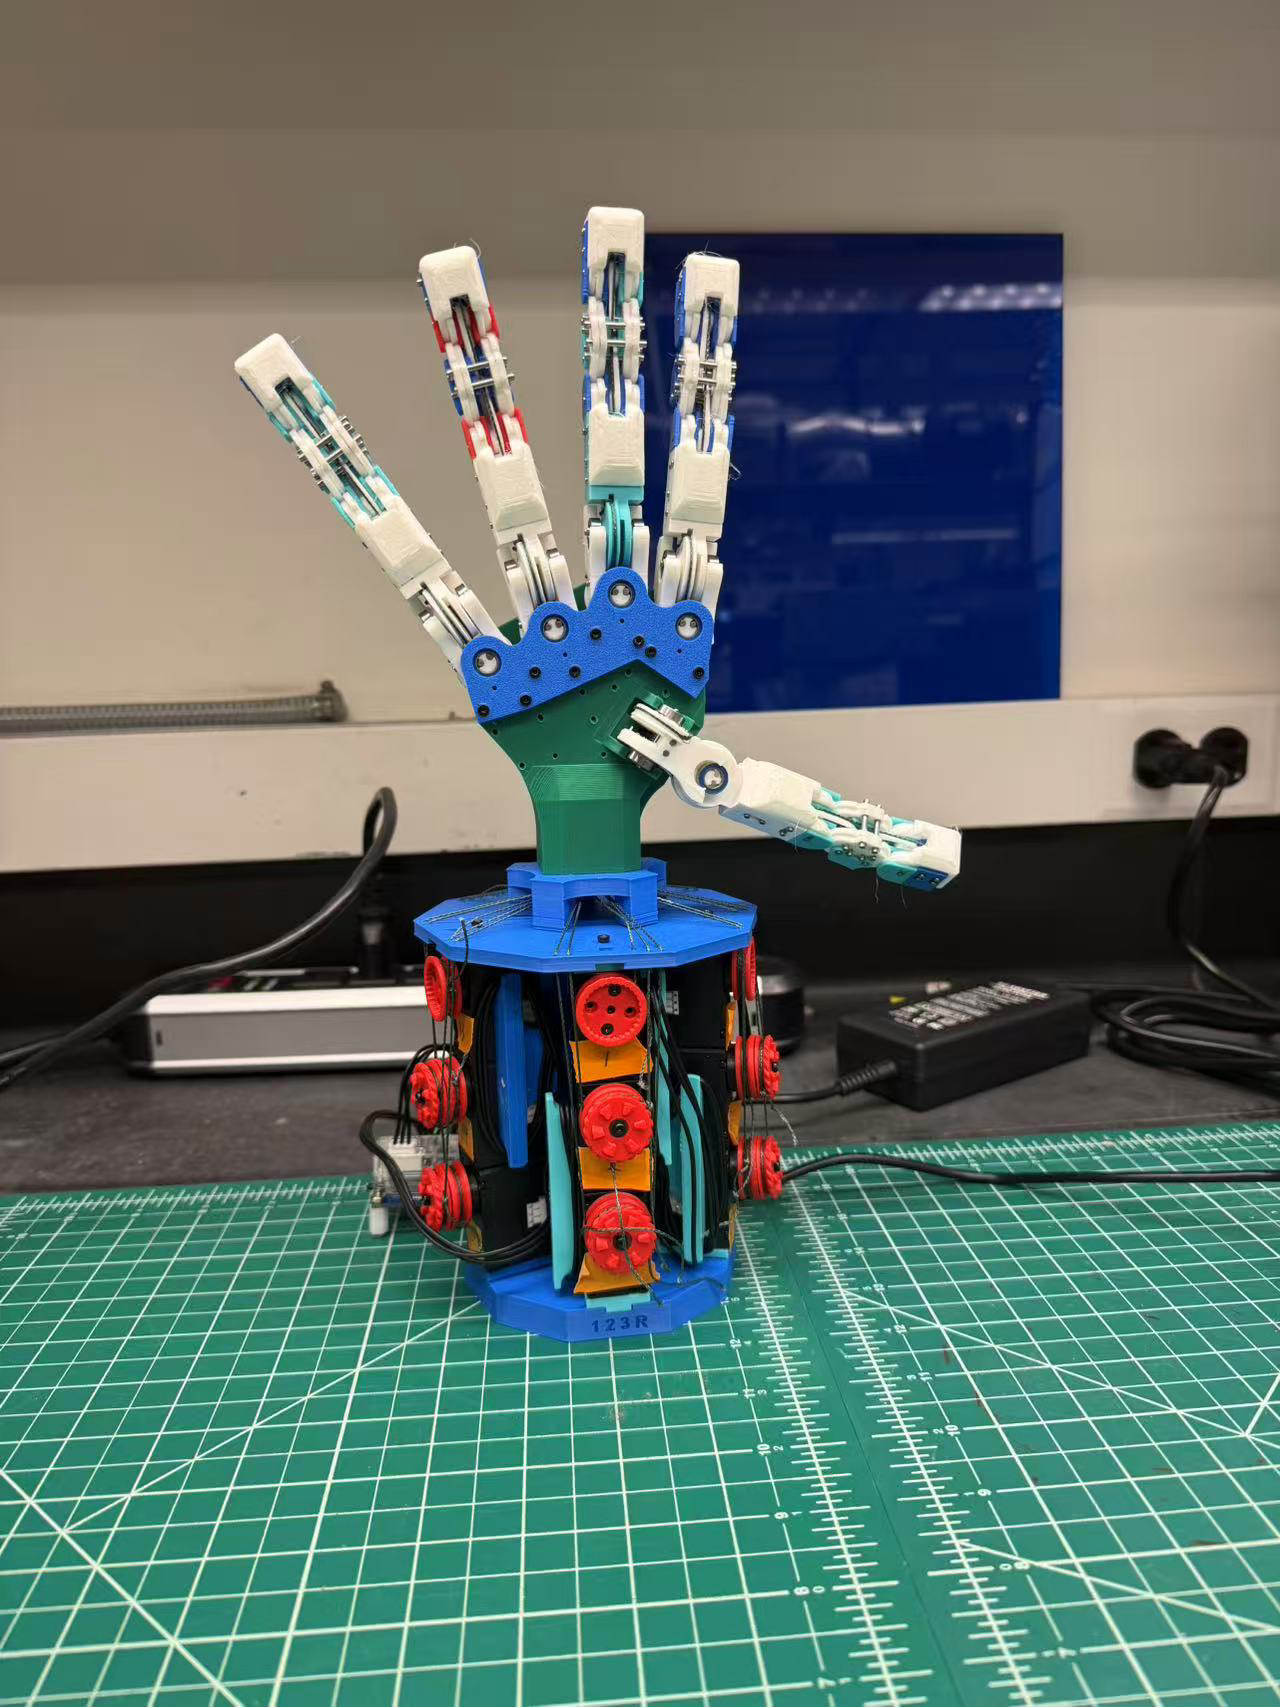
Teleoperation demonstration
Webcam-based MediaPipe tracking drives finger curl, MCP flexion, and finger spread. Thumb control interpolates recorded pinch poses. The integrated workflow includes stored calibration and smoothing to reduce jitter.
The mechanical design and control workflow build on CRAFT and its open-source guides. My contribution is assembly, integration, and the ongoing tactile hardware development.
Miniaturizing fingertip sensing
The tactile PCB is at layout stage. The planned SpikeATac-style design combines differential PVDF sensing for dynamic contact with four capacitive sensing elements for sustained contact. The design omits the accelerometer in the first version.
The central engineering tradeoff is sensor size versus signal quality. Component placement and fingertip packaging must preserve a useful signal while leaving room for the hand’s mechanics and wiring.
Build gallery